


When an automated forklift places a pallet several meters above the warehouse floor, pallet stability becomes more important than simply reaching the required lift height. A pallet that is leaning, poorly wrapped, shifted on the forks, or carrying an uneven load can create a serious operational risk during travel and rack placement.
Chinese automated forklift manufacturers can use a combination of LiDAR, vision sensors, fork-position sensors, load detection, localization data, and motion-control logic to identify abnormal load conditions. However, there is no single sensor configuration shared by every Chinese AGV manufacturer.
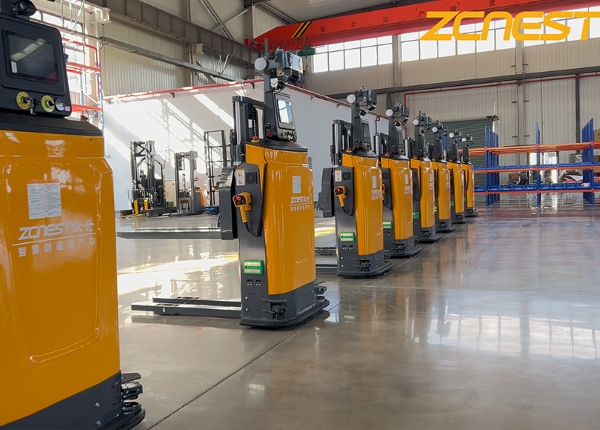
For a B2B buyer, the more important question is not simply “Does the AGV have a laser sensor?” but rather “What physical condition can the system detect, what decision does the software make, and can that behavior be demonstrated with my actual pallets and loads?”
A high-racking application can involve several different types of load instability. The pallet itself may be damaged or warped, the load may not be centered, shrink wrap may be loose, cartons may extend beyond the pallet, or the load may shift during acceleration and braking.
Uneven weight distribution across the pallet
Loose cartons or packages on the upper layers
Insufficient or damaged shrink wrap
Pallet deformation or broken boards
Load extending beyond the normal pallet profile
Load movement caused by acceleration, braking, or turning
Incorrect fork insertion or pallet misalignment
Excessive mast or fork deflection under heavy loads
These conditions are different from one another, so an AGV cannot necessarily detect all of them with one sensor. A good system combines physical sensing with predefined operating rules.
Depending on the vehicle design, Chinese automated forklifts may use 2D LiDAR, 3D LiDAR, laser scanners, depth cameras, industrial cameras, or combinations of these technologies.
A navigation LiDAR is primarily designed to localize the vehicle and understand the surrounding environment. It should not automatically be described as a dedicated pallet-stability sensor. Some systems use additional sensing specifically for fork alignment, pallet detection, rack positioning, or load-profile verification.
For example, a 3D sensing system can potentially provide information about the spatial profile of a pallet or load. If the measured geometry differs significantly from an expected profile, the fleet controller may be configured to slow down, stop, generate an alarm, or require operator intervention.
However, the exact detection capability depends on sensor mounting position, field of view, resolution, software algorithms, lighting conditions, pallet geometry, and the type of load being transported.
| Technology | Potential Function | Important Limitation |
|---|---|---|
| 2D LiDAR | Obstacle and environmental detection | Limited information about three-dimensional load geometry |
| 3D LiDAR | Three-dimensional object and profile detection | Performance depends on mounting, resolution, surfaces, and software |
| Industrial camera | Visual inspection and pallet/load recognition | Lighting, shadows, reflective surfaces, and occlusion can affect results |
| Depth camera | Depth and geometric information | Range and performance vary by hardware and environment |
| Fork/load sensors | Load presence, fork position, or related mechanical conditions | Does not necessarily detect loose packaging or load tilt |
Potentially, yes, but the detection method must be defined in the project specification. A forklift can detect some abnormal conditions by comparing sensor measurements against an expected pallet or load profile.
For example, if a vision or 3D sensing system measures the upper surface of a pallet load and detects a significant change in its expected geometry, the software could classify the load as abnormal.
Another approach is to combine load-position information with vehicle motion data. If the pallet is detected correctly at pickup but its geometry or position changes during subsequent movement, the system can use predefined thresholds to trigger an operational response.
But buyers should not assume that every AGV continuously measures pallet tilt during travel. Many systems are primarily designed to detect obstacles, pallet position, fork alignment, and vehicle localization. Continuous load-stability monitoring is an additional functional requirement that should be explicitly requested.
Not necessarily.
A loose piece of shrink wrap can be difficult for an automated forklift to distinguish from a harmless piece of packaging, a label, a hanging strap, or another object. Whether the vehicle stops depends on what the onboard sensors can actually see and how the safety and navigation software has been configured.
If a loose material enters a protective field monitored by a safety scanner, the vehicle may perform a protective stop. This is different from the system understanding that the pallet itself is unstable.
For example, a safety scanner may detect an object entering a protected area in front of the vehicle. It does not necessarily know that the object is “loose shrink wrap.” The resulting response may simply be a safety stop based on the detected object and its position.
If the customer specifically wants the AGV to recognize loose packaging as a load-quality problem, that should be treated as a separate machine-vision or load-inspection requirement and tested with representative packaging during FAT and SAT.
The onboard computer generally does not calculate pallet stability from one simple “tilt sensor.” The decision can involve several data sources and control conditions.
Sensor data identifies the pallet, load, obstacle, or abnormal geometry.
Vehicle localization determines the AGV's position and orientation.
Lift and fork feedback provides information about the handling state.
Motion-control parameters define allowable acceleration, deceleration, turning, and lifting behavior.
Software rules compare the current condition against predefined thresholds.
The control system determines whether to continue, reduce speed, stop, retry, or request human intervention.
In a high-bay application, the risk model can also be linked to lift height and load characteristics. A vehicle may use different movement parameters when carrying a load at low height compared with transporting a pallet after high-level retrieval or before rack placement.
This is why the phrase “AI-based pallet stability detection” is not sufficient for an RFQ. The buyer should ask exactly what sensors are used, what condition is detected, what threshold triggers an action, and what action the AGV takes.
In many fleet-control systems, operating parameters can be configured by operating zone, route, task, vehicle state, or load condition. The exact level of customization is supplier-specific.
For delicate or unstable products, a project may define a different motion profile with lower acceleration, lower deceleration, reduced turning speed, or controlled lifting and lowering speeds.
For example, the warehouse could define different profiles for:
Standard pallet loads
Fragile cartons
Tall or top-heavy loads
High-value products
Loads transported at higher lift positions
The important point is that “custom speed profile” should not be interpreted as unrestricted access to every low-level control parameter. Some parameters may be configurable by authorized users, while safety-critical parameters may require manufacturer engineering access.
For a production warehouse, this permission structure is useful because it prevents an operator from accidentally changing safety-critical motion limits while still allowing approved users to configure operational parameters.
If pallet stability is important to your warehouse, avoid writing only “AGV must detect unstable pallets.” Turn the requirement into measurable functions.
| RFQ Requirement | What to Ask the Supplier |
|---|---|
| Load detection | What sensor detects the pallet and load profile? |
| Tilt detection | Can the system identify a defined load inclination or abnormal geometry? |
| Loose packaging | Can the vision system identify representative loose film, straps, or protruding packaging? |
| High-level operation | What changes in sensing and motion control occur at maximum lift height? |
| Abnormal condition | Does the AGV stop, slow down, retry, or request operator intervention? |
| Motion profile | Can acceleration, braking, turning, and lift speeds be configured by authorized users? |
| Event records | Are abnormal-load events recorded in the fleet-management system? |
A supplier demonstration using an ideal, perfectly wrapped pallet is not enough for a warehouse that handles variable loads.
FAT should use representative pallets and loads that reproduce the customer's actual operating conditions. If the system is expected to detect unstable loads, deliberately introduce controlled variations within safe test procedures.
Centered and off-center loads
Different pallet conditions
Tall loads
Different wrapping conditions
Representative cartons or containers
Different payload weights and load centers
Travel and braking conditions
High-level rack placement conditions
The acceptance test should record the sensor response, vehicle response, alarm information, stopping behavior, recovery procedure, and whether the event appears in the fleet-management records.
The same representative pallet profiles should then be used during SAT in the customer's warehouse. This is particularly important because lighting, rack geometry, floor conditions, Wi-Fi behavior, traffic, and actual packaging can differ significantly from the factory environment.
For high-racking automated forklift projects, pallet stability is a system-level requirement rather than a single-component specification.
LiDAR, cameras, fork sensors, lift feedback, localization, motion control, and fleet software can work together, but their actual capabilities vary between AGV models and suppliers. A navigation laser does not automatically provide pallet-tilt detection, and a safety scanner does not automatically understand whether shrink wrap is loose.
For procurement, the safest approach is to define the abnormal conditions that matter to your warehouse, specify the required vehicle response, and make those functions part of FAT/SAT acceptance testing.
If your warehouse handles high-value, fragile, tall, or irregular pallet loads, ask the Chinese AGV supplier for a sensor architecture diagram, load-detection logic, configurable motion parameters, alarm records, and a representative pallet stability test before finalizing the purchase.





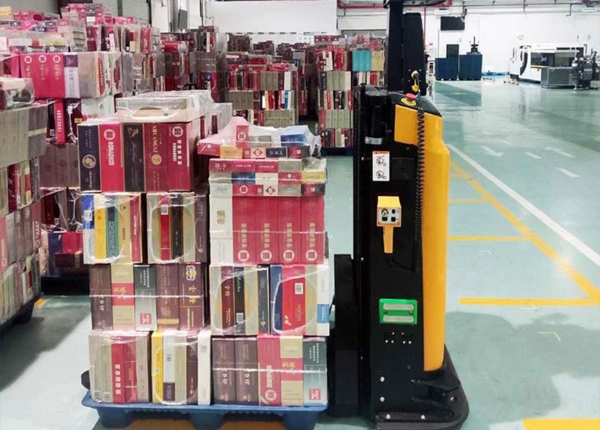
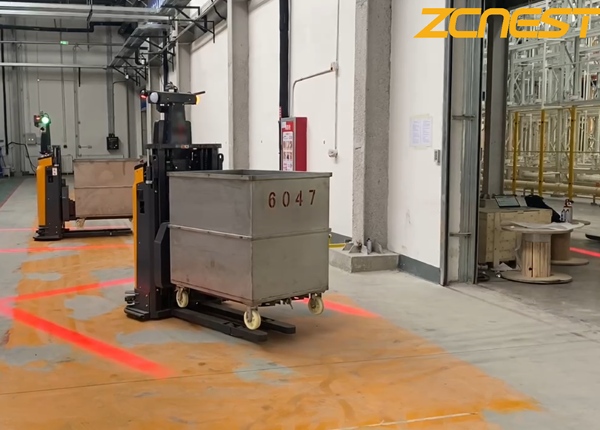







 Chinese
 English




